Loading...
Searching...
No Matches
trajopt::CubicHermitePoseSplineHolonomic Class Reference
#include <trajopt/spline/cubic_hermite_pose_spline_holonomic.hpp>
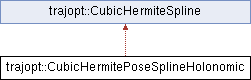
Inheritance diagram for trajopt::CubicHermitePoseSplineHolonomic:
Public Types | |
| using | PoseWithCurvature = std::pair<Pose2d, double> |
| Pose2d with curvature. | |
Public Member Functions | |
| CubicHermitePoseSplineHolonomic (std::array< double, 2 > x_initial_control_vector, std::array< double, 2 > x_final_control_vector, std::array< double, 2 > y_initial_control_vector, std::array< double, 2 > y_final_control_vector, Rotation2d r0, Rotation2d r1) | |
| Rotation2d | GetCourse (double t) const |
| Rotation2d | get_heading (double t) const |
| double | get_heading_rate (double t) const |
| std::optional< PoseWithCurvature > | get_point (double t, bool is_differential) const |
Detailed Description
Represents a cubic pose spline, which is a specific implementation of a cubic hermite spline.
Constructor & Destructor Documentation
◆ CubicHermitePoseSplineHolonomic()
|
inline |
Constructs a cubic pose spline.
- Parameters
-
x_initial_control_vector The control vector for the initial point in the x dimension. x_final_control_vector The control vector for the final point in the x dimension. y_initial_control_vector The control vector for the initial point in the y dimension. y_final_control_vector The control vector for the final point in the y dimension. r0 Initial heading. r1 Final heading.
Member Function Documentation
◆ get_heading()
|
inline |
Return heading at point t.
- Parameters
-
t The point t
- Returns
- The heading at point t.
◆ get_heading_rate()
|
inline |
Return heading rate at point t.
- Parameters
-
t The point t
- Returns
- The heading rate at point t.
◆ get_point()
|
inline |
Gets the pose and curvature at some point t on the spline.
- Parameters
-
t The point t is_differential Whether the drivetrain is a differential drive.
- Returns
- The pose and curvature at that point.
◆ GetCourse()
|
inline |
Return course at point t.
- Parameters
-
t The point t
- Returns
- The course at point t.
The documentation for this class was generated from the following file:
- include/trajopt/spline/cubic_hermite_pose_spline_holonomic.hpp
