Loading...
Searching...
No Matches
trajopt::CubicHermiteSpline Class Reference
Represents a hermite spline of degree 3. More...
#include <trajopt/spline/cubic_hermite_spline.hpp>
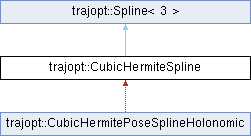
Inheritance diagram for trajopt::CubicHermiteSpline:
Public Member Functions | |
| CubicHermiteSpline (std::array< double, 2 > x_initial_control_vector, std::array< double, 2 > x_final_control_vector, std::array< double, 2 > y_initial_control_vector, std::array< double, 2 > y_final_control_vector) | |
| const Eigen::Matrix< double, 6, 3+1 > & | coefficients () const override |
| const ControlVector & | get_initial_control_vector () const override |
| const ControlVector & | get_final_control_vector () const override |
| Public Member Functions inherited from trajopt::Spline< 3 > | |
| std::optional< PoseWithCurvature > | get_point (double t) const |
Additional Inherited Members | |
| Public Types inherited from trajopt::Spline< 3 > | |
| using | PoseWithCurvature |
| Pose2d with curvature. | |
Detailed Description
Represents a hermite spline of degree 3.
Constructor & Destructor Documentation
◆ CubicHermiteSpline()
|
inline |
Constructs a cubic hermite spline with the specified control vectors. Each control vector contains info about the location of the point and its first derivative.
- Parameters
-
x_initial_control_vector The control vector for the initial point in the x dimension. x_final_control_vector The control vector for the final point in the x dimension. y_initial_control_vector The control vector for the initial point in the y dimension. y_final_control_vector The control vector for the final point in the y dimension.
Member Function Documentation
◆ coefficients()
|
inlineoverridevirtual |
◆ get_final_control_vector()
|
inlineoverridevirtual |
Returns the final control vector that created this spline.
- Returns
- The final control vector that created this spline.
Implements trajopt::Spline< 3 >.
◆ get_initial_control_vector()
|
inlineoverridevirtual |
Returns the initial control vector that created this spline.
- Returns
- The initial control vector that created this spline.
Implements trajopt::Spline< 3 >.
The documentation for this class was generated from the following file:
- include/trajopt/spline/cubic_hermite_spline.hpp
